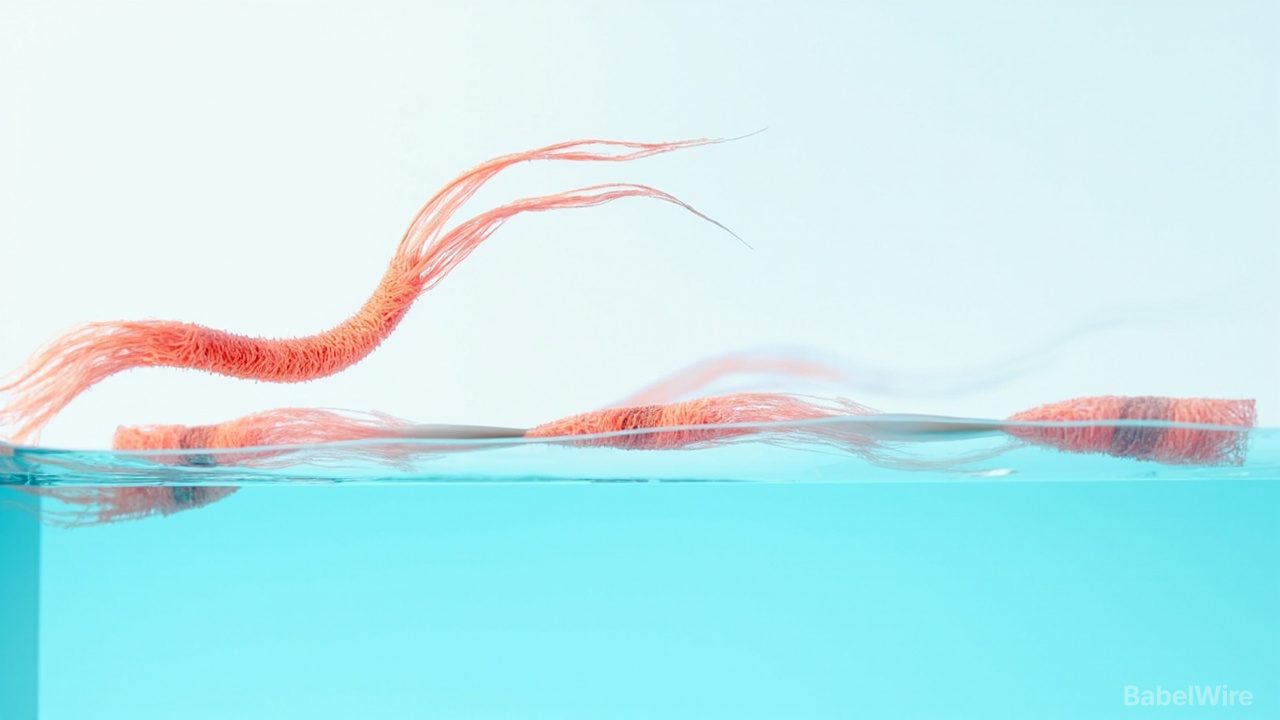
Robotics keeps borrowing from biology, and a report highlighted by Golem describes a biohybrid muscle that can jump, swim and walk.
Biohybrid systems put living cells to work as actuators. Muscle tissue seeded onto a scaffold contracts when stimulated, and unlike a servo it carries its own power source in the form of stored metabolic energy — at the cost of having to be kept alive. Up to now such constructs have mostly demonstrated a single trick: a contractile ring that pinches, a strip that pulls, a small swimmer that undulates.
The construct described in the new work is credited with three: jumping, swimming and walking. Those are not variations on one motion but three different mechanical strategies. Jumping means generating a rapid burst of force against a stored elastic load. Swimming means rhythmic, low-force actuation against a fluid. Walking means phased, load-bearing cycles that move a body across a surface. Getting one piece of engineered tissue to deliver all three is the interesting part, because each demands a different profile of force, timing and energy management.
The appeal of the approach is what living tissue does that synthetic actuators struggle with: self-maintenance and, in principle, self-repair, plus very high power density for short bursts. The costs are equally real — the tissue needs a medium, does not survive indefinitely, and produces force that is harder to calibrate than a motor's.
Why it matters: locomotion remains the hardest part of small-scale robot design, and actuators set the ceiling on what a robot can do. Demonstrating multiple modes in a single biological actuator points toward robots that reconfigure their movement instead of being locked into one gait.
Golem has the details.