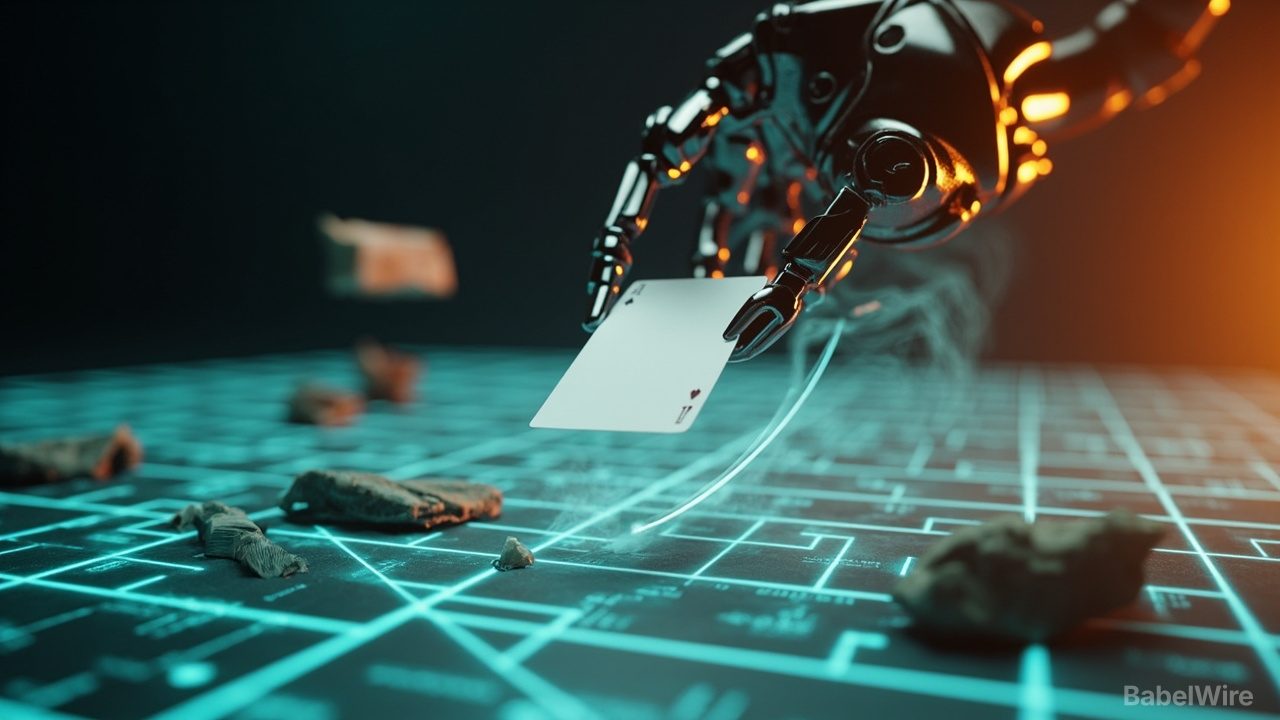
Google DeepMind's robotics simulation team released MuJoCo 4.0.0 on 6 November and announced it the following day. It is the engine's first major version since MuJoCo 3.0 in 2023 — 39 releases have shipped in between — and the team deliberately held back the 4.0 number for a step change rather than a compatibility break. MuJoCo Playground 1.0 shipped alongside it, and the repository was climbing GitHub's trending list on 10 November.
The headline feature is speculative contacts, switched on with a single flag. Conventional collision detection only sees a contact once two shapes already overlap, so at large timesteps a fast or thin object can pass clean through an obstacle between two steps. Speculative contacts sweep fast-moving geometry ahead within a step, keep bodies on the separated side and generate up to four contact points, so a thin plate lands flat without shrinking the timestep. In the team's tests a robot arm caught a 0.7 mm playing card falling at more than 2 m/s every time at a 16 ms timestep, where conventional detection misses it above 8 ms. Humanoid stair climbing and thin-object grasping ran 6 to 9 times faster because larger timesteps became usable. In 4.0 the feature covers convex primitives and meshes on CPU only; height fields, signed distance fields, flexes, MJX and MuJoCo Warp are to follow.
Soft bodies graduate from experimental plugins to native deformables, solved implicitly together with rigid bodies, joints and tendons. A new discrete integrator keeps stiff cables, thin shells and 3D solids stable at 5–10x larger timesteps; cloth can be made penetration-free with IPC contact; and plasticity arrives — joints and tendons yield permanently past a threshold, so a wire stays bent, clay keeps a dent, metal foil and folded paper keep their creases. One-dimensional elastic rods with bending and twist match textbook cantilever deflection within 0.5% on CPU and on Warp, replacing the old composite element and the cable plugin.
The decade-old fixed-function OpenGL 1.5 viewer is superseded. MuJoCo Studio leaves the experimental folder as a C++ and Python SDK of composable simulation, Dear ImGui and rendering parts, with a default Studio App, hot reload of plugins and model files while the simulation runs, and a web mode that streams a live session to a browser where a colleague can take control. Rendering moves to Filament with metallic-roughness materials, image-based lighting and soft shadows; any model opens at live.mujoco.org with nothing installed. The old simulate viewer stays in maintenance mode.
Context for the scale of the release: the engine sees roughly 3.6 million PyPI downloads a month, has more than 16,000 GitHub stars, and has taken about 2,000 commits from 45-plus external contributors since 3.0. The collision stack was rebuilt across the 3.x series — native convex collision replacing libccd, multi-point contacts by default, multithreaded collision and solve, around a 4x speedup — and speculative contacts are what that work was building toward.
Upgrading is not free. pip uninstall is required before installing 4.0; Python 3.10 support is dropped, with 3.11 to 3.15 remaining; the composite element, the cable and shell elasticity plugins and flexvert equalities are gone in favour of flexcomp; the tendon side-site wrapping rule changed, which can move existing models; RK4 is now properly fourth-order accurate for ball and free joints, changing those simulations; and the compiler now rejects some models that previously loaded. Downstream libraries such as mink, mjlab and MuJoCo MPC may need their own releases first. The licence stays Apache-2.0, and the robotics ecosystem — NVIDIA, Disney Research, Toyota Research Institute on the Newton engine under the Linux Foundation — keeps building on the same core.



